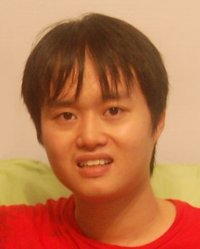
I am the Deputy CEO and CTO of a VinGroup Robotics subsidiary aiming to lead robotics innovation. I am also an affiliated faculty member in the college of EECS at VinUni.
I earned my Ph.D. in Robotics from Kyung Hee University (2009), followed by a postdoctoral at NUS working with David Hsu and Lee Wee Sun , and a group lead at the University of Stuttgart working with Marc Toussaint. Later I became a Lecturer (Assistant Professor) at Queen’s University Belfast. From 2020 to 2025, I was a roboticist at Bosch Center of AI (BCAI), and contributing over 30 patent applications (including 6 granted U.S. patents). Throughout my career, I am fortunate to (co-)mentor more than 15 Ph.D. and 40 M.Sc. students.
Warning
Problem: The current name of your GitHub Pages repository ("Solution: Please consider renaming the repository to "
http://".
However, if the current repository name is intended, you can ignore this message by removing "{% include widgets/debug_repo_name.html %}" in index.html.
Action required
Problem: The current root path of this site is "baseurl ("_config.yml.
Solution: Please set the
baseurl in _config.yml to "Education
-
 Kyung Hee UniversityDepartment of Computer Engineering
Ph.D in AI Robotics2005 - 2009 -
 Hanoi University of Science and TechnologyB.S. in Computer Science2000 - 2005
Recent Publications (view more )
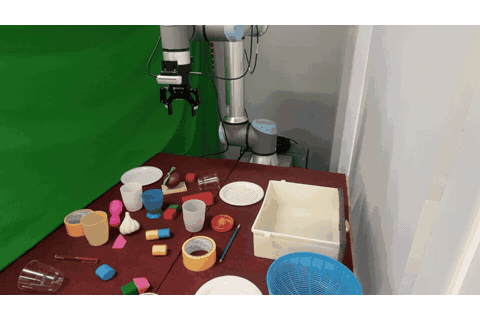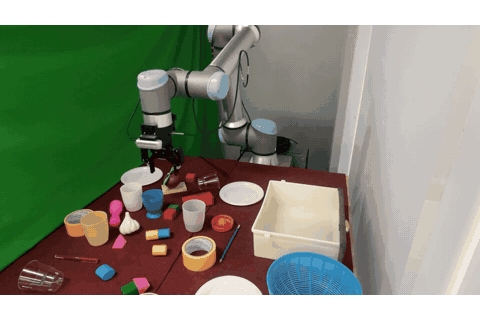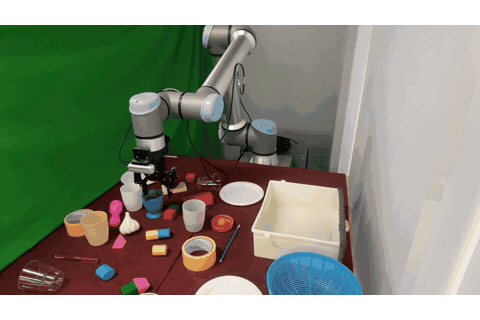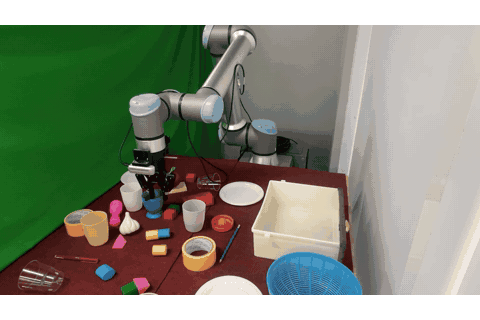
GloVLA: Let Geometry Move and Local VLA Interact for Robust Object-Centric Manipulation in Unstructured Environments
Truong Thanh Nguyen and Huy Hoang Nguyen and Ha Anh Nguyen and Binh Khanh Dinh and Ngo Anh Vien and Duy Nguyen Ho Minh and Minh Nhat Vu and Ngan Le
arXiv preprint
GloVLA: Let Geometry Move and Local VLA Interact for Robust Object-Centric Manipulation in Unstructured Environments
Truong Thanh Nguyen and Huy Hoang Nguyen and Ha Anh Nguyen and Binh Khanh Dinh and Ngo Anh Vien and Duy Nguyen Ho Minh and Minh Nhat Vu and Ngan Le
arXiv preprint
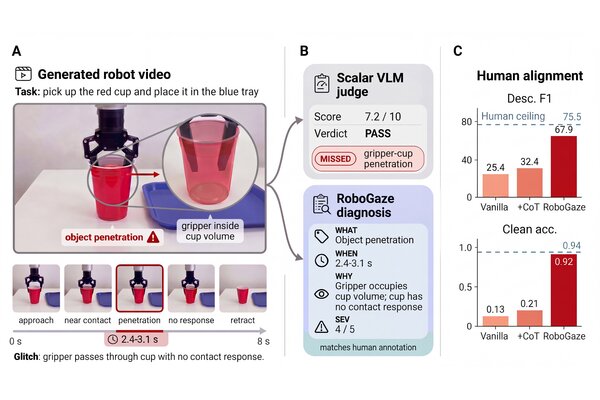
RoboGaze: Evaluating Robot World Models via Structured Vision-Language Analysis
Minh-Loi Nguyen and Nghiem Tuong Diep and Hung Khang Nguyen and Minh Le and Doanh Le Thien and Hoang H. Tran and Dung D. Le and Vu N. Duong and Daniel Sonntag and An Thai Le and Duy Minh Ho Nguyen and Ngo Anh Vien and Tran Van Nhiem
arXiv preprint
RoboGaze: Evaluating Robot World Models via Structured Vision-Language Analysis
Minh-Loi Nguyen and Nghiem Tuong Diep and Hung Khang Nguyen and Minh Le and Doanh Le Thien and Hoang H. Tran and Dung D. Le and Vu N. Duong and Daniel Sonntag and An Thai Le and Duy Minh Ho Nguyen and Ngo Anh Vien and Tran Van Nhiem
arXiv preprint
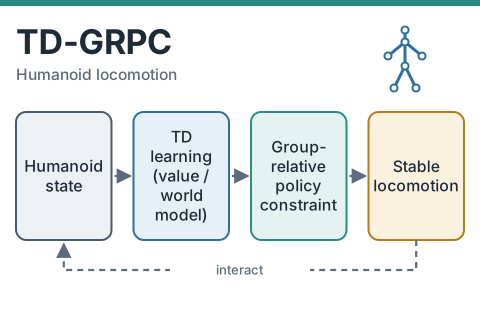
TD-GRPC: Temporal Difference Learning with Group Relative Policy Constraint for Humanoid Locomotion
Khang Nguyen and An T. Le and Khai Nguyen and Jan Peters and Manfred Huber and Ngo Anh Vien and Minh Nhat Vu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
TD-GRPC: Temporal Difference Learning with Group Relative Policy Constraint for Humanoid Locomotion
Khang Nguyen and An T. Le and Khai Nguyen and Jan Peters and Manfred Huber and Ngo Anh Vien and Minh Nhat Vu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Start Right, Arrive Right: Asynchronous Execution via Initial Noise Selection
Trong-Bao Ho and Quang-Tan Nguyen and Thien-Loc Ha and Gia-Binh Nguyen and Viet-Thanh Nguyen and Long Dinh and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
Conference on Robot Learning (CoRL)
Start Right, Arrive Right: Asynchronous Execution via Initial Noise Selection
Trong-Bao Ho and Quang-Tan Nguyen and Thien-Loc Ha and Gia-Binh Nguyen and Viet-Thanh Nguyen and Long Dinh and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
Conference on Robot Learning (CoRL)
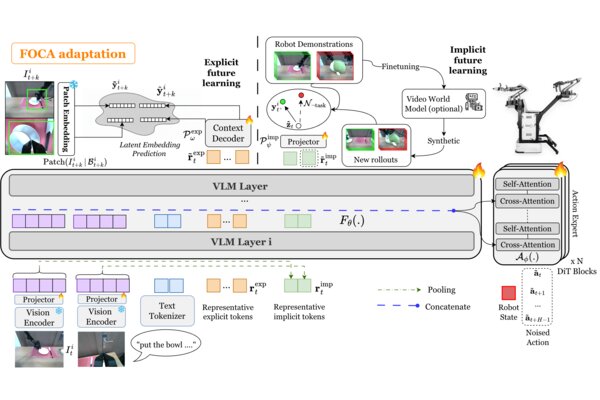
FOCA: Future-Oriented Conditioning for Data-Efficient Vision-Language-Action Adaptation
Duc Minh Nguyen and Nghiem Tuong Diep and Binh Gia Nguyen and Trong-Bao Ho and Doanh Le and Tan Q. Nguyen and Thien-Loc Ha and Nhiem Tran and Bao Thach and Nhat X. Tran and Tuan A. Tran and Artur Habuda and Philip Lund Møller and Tran Nguyen Le and Daniel Sonntag and Matthias Niepert and Khoa D. Doan and Vu Duong and Hung Ngo and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
International Conference on Machine Learning (ICML)
FOCA: Future-Oriented Conditioning for Data-Efficient Vision-Language-Action Adaptation
Duc Minh Nguyen and Nghiem Tuong Diep and Binh Gia Nguyen and Trong-Bao Ho and Doanh Le and Tan Q. Nguyen and Thien-Loc Ha and Nhiem Tran and Bao Thach and Nhat X. Tran and Tuan A. Tran and Artur Habuda and Philip Lund Møller and Tran Nguyen Le and Daniel Sonntag and Matthias Niepert and Khoa D. Doan and Vu Duong and Hung Ngo and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
International Conference on Machine Learning (ICML)
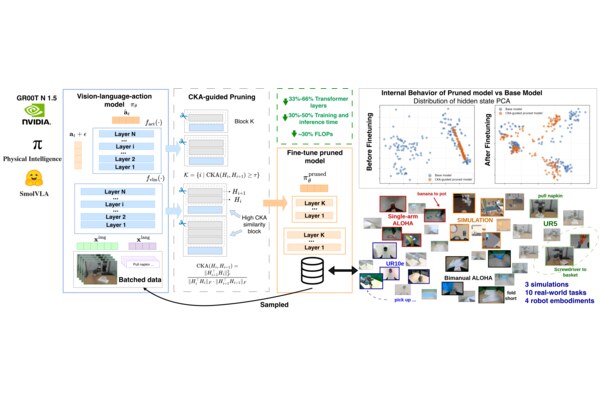
Finetuning Vision-Language-Action Models Requires Fewer Layers Than You Think
Gia-Binh Nguyen and Trong-Bao Ho and Thien-Loc Ha and Khoa Vo and Philip Lund Møller and Quang T. Nguyen and Long Dinh and Tung M. Luu and Tuan Quang Dam and Vu Duong and Trung Le and Nghi D. Q. Bui and Minh Vu and Tran Nguyen Le and An Thai Le and Hong Anh Le and Daniel Sonntag and James Zou and Jan Peters and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
Finetuning Vision-Language-Action Models Requires Fewer Layers Than You Think
Gia-Binh Nguyen and Trong-Bao Ho and Thien-Loc Ha and Khoa Vo and Philip Lund Møller and Quang T. Nguyen and Long Dinh and Tung M. Luu and Tuan Quang Dam and Vu Duong and Trung Le and Nghi D. Q. Bui and Minh Vu and Tran Nguyen Le and An Thai Le and Hong Anh Le and Daniel Sonntag and James Zou and Jan Peters and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
EquiVLA: A General Framework for Rotationally Equivariant Vision-Language-Action Models
Thien-Loc Ha and Quang-Tan Nguyen and Trong-Bao Ho and Long Dinh and Minh Duc Nguyen and Gia-Binh Nguyen and Pham Tri Quang and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
arXiv preprint
EquiVLA: A General Framework for Rotationally Equivariant Vision-Language-Action Models
Thien-Loc Ha and Quang-Tan Nguyen and Trong-Bao Ho and Long Dinh and Minh Duc Nguyen and Gia-Binh Nguyen and Pham Tri Quang and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
arXiv preprint
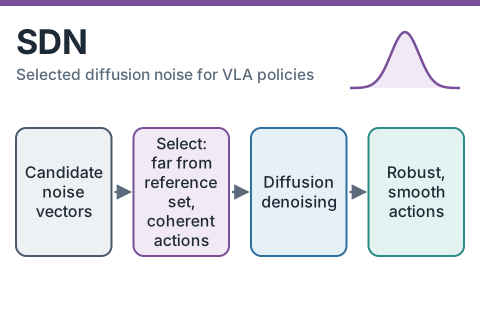
Self-Improving VLA Policies: Selected Diffusion Noise for Spurious-Robust Action Smoothing
Duc Minh Nguyen and Bao-Ngoc Dao and Tung M. Luu and Binh Gia Nguyen and Vinh Tong and Anji Liu and Vu N. Duong and Dung D. Le and Daniel Sonntag and Trung Le and Ngan Le and Jan Peters and An Thai Le and Minh Nhat Vu and Mathias Niepert and Khoa D. Doan and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
Self-Improving VLA Policies: Selected Diffusion Noise for Spurious-Robust Action Smoothing
Duc Minh Nguyen and Bao-Ngoc Dao and Tung M. Luu and Binh Gia Nguyen and Vinh Tong and Anji Liu and Vu N. Duong and Dung D. Le and Daniel Sonntag and Trung Le and Ngan Le and Jan Peters and An Thai Le and Minh Nhat Vu and Mathias Niepert and Khoa D. Doan and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
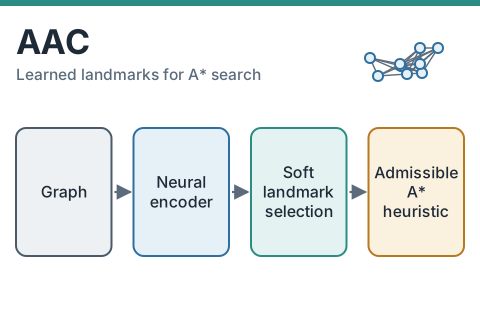
AAC: Admissible-by-Architecture Differentiable Landmark Compression for ALT
An T. Le and Ngo Anh Vien
arXiv preprint
AAC: Admissible-by-Architecture Differentiable Landmark Compression for ALT
An T. Le and Ngo Anh Vien
arXiv preprint
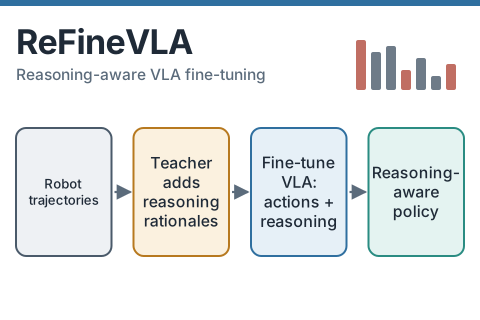
ReFineVLA: Multimodal Reasoning-Aware Generalist Robotic Policies via Teacher-Guided Fine-Tuning
Tuan Van Vo and Tan Q. Nguyen and Khang Nguyen and Nhat Xuan Tran and Duy H. M. Nguyen and An T. Le and Ngo Anh Vien and Minh Nhat Vu
arXiv preprint
ReFineVLA: Multimodal Reasoning-Aware Generalist Robotic Policies via Teacher-Guided Fine-Tuning
Tuan Van Vo and Tan Q. Nguyen and Khang Nguyen and Nhat Xuan Tran and Duy H. M. Nguyen and An T. Le and Ngo Anh Vien and Minh Nhat Vu
arXiv preprint
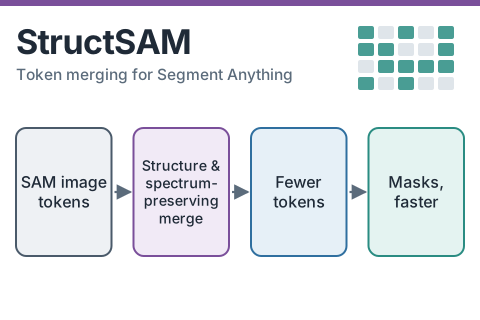
StructSAM: Structure- and Spectrum-Preserving Token Merging for Segment Anything Models
Duy M. H. Nguyen and Tuan A. Tran and Duong Nguyen and Siwei Xie and Trung Q. Nguyen and Mai T. N. Truong and Daniel Palenicek and An T. Le and Michael Barz and TrungTin Nguyen and Tuan Dam and Ngan Le and Minh Vu and Khoa D. Doan and Ngo Anh Vien and Pengtao Xie and James Zou and Daniel Sonntag and Jan Peters and Mathias Niepert
arXiv preprint
StructSAM: Structure- and Spectrum-Preserving Token Merging for Segment Anything Models
Duy M. H. Nguyen and Tuan A. Tran and Duong Nguyen and Siwei Xie and Trung Q. Nguyen and Mai T. N. Truong and Daniel Palenicek and An T. Le and Michael Barz and TrungTin Nguyen and Tuan Dam and Ngan Le and Minh Vu and Khoa D. Doan and Ngo Anh Vien and Pengtao Xie and James Zou and Daniel Sonntag and Jan Peters and Mathias Niepert
arXiv preprint
How Many Tokens Do 3D Point Cloud Transformer Architectures Really Need?
Tuan Anh Tran and Duy Minh Ho Nguyen and Hoai-Chau Tran and Michael Barz and Khoa D Doan and Roger Wattenhofer and Vien Anh Ngo and Mathias Niepert and Daniel Sonntag and Paul Swoboda
Advances in Neural Information Processing Systems (NeurIPS)
How Many Tokens Do 3D Point Cloud Transformer Architectures Really Need?
Tuan Anh Tran and Duy Minh Ho Nguyen and Hoai-Chau Tran and Michael Barz and Khoa D Doan and Roger Wattenhofer and Vien Anh Ngo and Mathias Niepert and Daniel Sonntag and Paul Swoboda
Advances in Neural Information Processing Systems (NeurIPS)
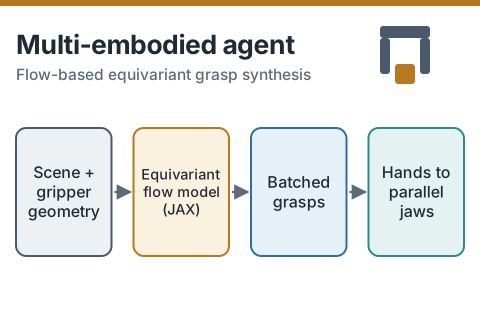
Towards a Multi-Embodied Grasping Agent
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
arXiv preprint
Towards a Multi-Embodied Grasping Agent
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
arXiv preprint
Enhancing Exploration With Diffusion Policies in Hybrid Off-Policy RL: Application to Non-Prehensile Manipulation
Huy Le and Tai Hoang and Miroslav Gabriel and Gerhard Neumann and Ngo Anh Vien
IEEE Robotics Autom. Lett. (RAL)
Enhancing Exploration With Diffusion Policies in Hybrid Off-Policy RL: Application to Non-Prehensile Manipulation
Huy Le and Tai Hoang and Miroslav Gabriel and Gerhard Neumann and Ngo Anh Vien
IEEE Robotics Autom. Lett. (RAL)
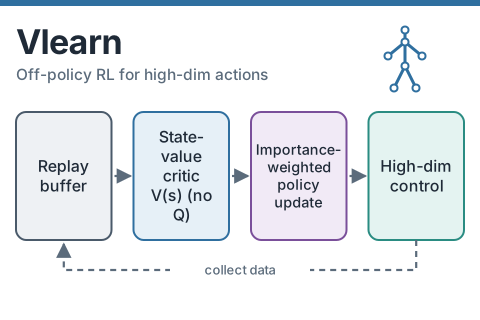
Efficient Off-Policy Learning for High-Dimensional Action Spaces
Fabian Otto and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
Efficient Off-Policy Learning for High-Dimensional Action Spaces
Fabian Otto and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
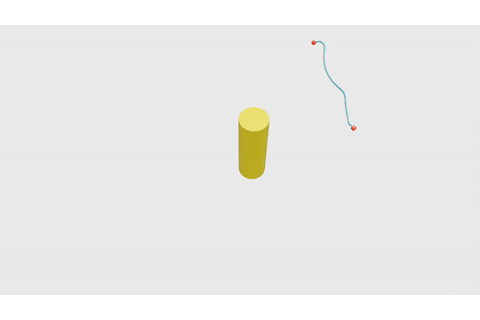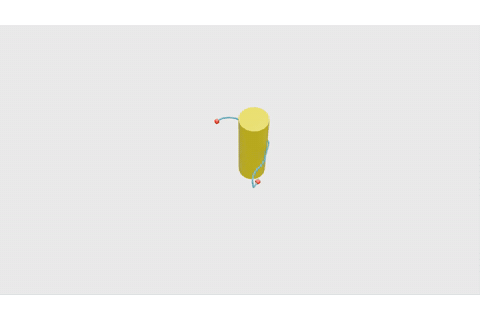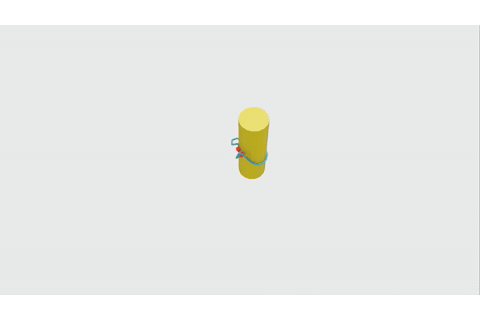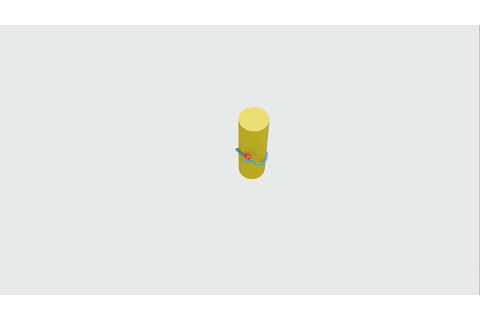
Geometry-aware RL for Manipulation of Varying Shapes and Deformable Objects
Tai Hoang and Huy Le and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
Geometry-aware RL for Manipulation of Varying Shapes and Deformable Objects
Tai Hoang and Huy Le and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
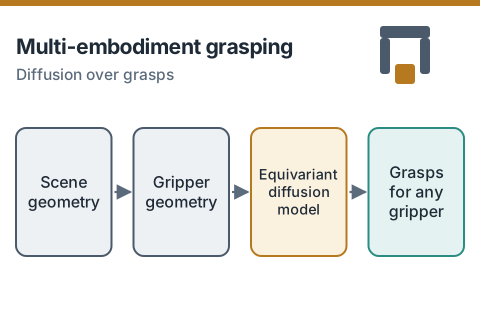
Diffusion for Multi-Embodiment Grasping
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
IEEE Robotics Autom. Lett. (RAL)
Diffusion for Multi-Embodiment Grasping
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
IEEE Robotics Autom. Lett. (RAL)