2026
GloVLA: Let Geometry Move and Local VLA Interact for Robust Object-Centric Manipulation in Unstructured Environments
Truong Thanh Nguyen and Huy Hoang Nguyen and Ha Anh Nguyen and Binh Khanh Dinh and Ngo Anh Vien and Duy Nguyen Ho Minh and Minh Nhat Vu and Ngan Le
arXiv preprint
GloVLA: Let Geometry Move and Local VLA Interact for Robust Object-Centric Manipulation in Unstructured Environments
Truong Thanh Nguyen and Huy Hoang Nguyen and Ha Anh Nguyen and Binh Khanh Dinh and Ngo Anh Vien and Duy Nguyen Ho Minh and Minh Nhat Vu and Ngan Le
arXiv preprint
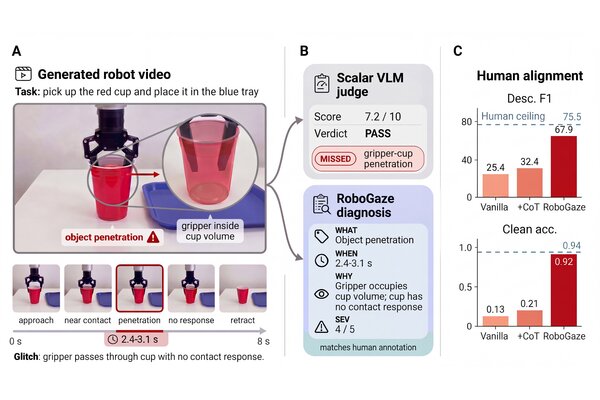
RoboGaze: Evaluating Robot World Models via Structured Vision-Language Analysis
Minh-Loi Nguyen and Nghiem Tuong Diep and Hung Khang Nguyen and Minh Le and Doanh Le Thien and Hoang H. Tran and Dung D. Le and Vu N. Duong and Daniel Sonntag and An Thai Le and Duy Minh Ho Nguyen and Ngo Anh Vien and Tran Van Nhiem
arXiv preprint
RoboGaze: Evaluating Robot World Models via Structured Vision-Language Analysis
Minh-Loi Nguyen and Nghiem Tuong Diep and Hung Khang Nguyen and Minh Le and Doanh Le Thien and Hoang H. Tran and Dung D. Le and Vu N. Duong and Daniel Sonntag and An Thai Le and Duy Minh Ho Nguyen and Ngo Anh Vien and Tran Van Nhiem
arXiv preprint
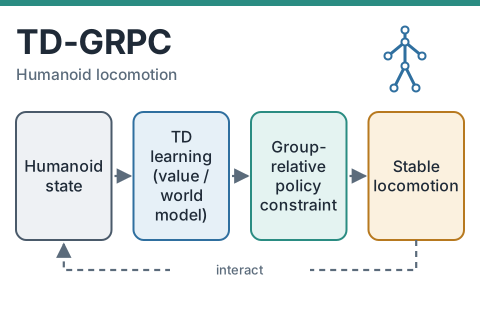
TD-GRPC: Temporal Difference Learning with Group Relative Policy Constraint for Humanoid Locomotion
Khang Nguyen and An T. Le and Khai Nguyen and Jan Peters and Manfred Huber and Ngo Anh Vien and Minh Nhat Vu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
TD-GRPC: Temporal Difference Learning with Group Relative Policy Constraint for Humanoid Locomotion
Khang Nguyen and An T. Le and Khai Nguyen and Jan Peters and Manfred Huber and Ngo Anh Vien and Minh Nhat Vu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Start Right, Arrive Right: Asynchronous Execution via Initial Noise Selection
Trong-Bao Ho and Quang-Tan Nguyen and Thien-Loc Ha and Gia-Binh Nguyen and Viet-Thanh Nguyen and Long Dinh and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
Conference on Robot Learning (CoRL)
Start Right, Arrive Right: Asynchronous Execution via Initial Noise Selection
Trong-Bao Ho and Quang-Tan Nguyen and Thien-Loc Ha and Gia-Binh Nguyen and Viet-Thanh Nguyen and Long Dinh and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
Conference on Robot Learning (CoRL)
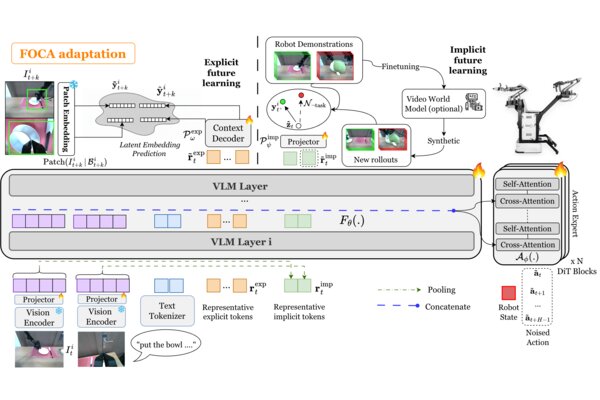
FOCA: Future-Oriented Conditioning for Data-Efficient Vision-Language-Action Adaptation
Duc Minh Nguyen and Nghiem Tuong Diep and Binh Gia Nguyen and Trong-Bao Ho and Doanh Le and Tan Q. Nguyen and Thien-Loc Ha and Nhiem Tran and Bao Thach and Nhat X. Tran and Tuan A. Tran and Artur Habuda and Philip Lund Møller and Tran Nguyen Le and Daniel Sonntag and Matthias Niepert and Khoa D. Doan and Vu Duong and Hung Ngo and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
International Conference on Machine Learning (ICML)
FOCA: Future-Oriented Conditioning for Data-Efficient Vision-Language-Action Adaptation
Duc Minh Nguyen and Nghiem Tuong Diep and Binh Gia Nguyen and Trong-Bao Ho and Doanh Le and Tan Q. Nguyen and Thien-Loc Ha and Nhiem Tran and Bao Thach and Nhat X. Tran and Tuan A. Tran and Artur Habuda and Philip Lund Møller and Tran Nguyen Le and Daniel Sonntag and Matthias Niepert and Khoa D. Doan and Vu Duong and Hung Ngo and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
International Conference on Machine Learning (ICML)
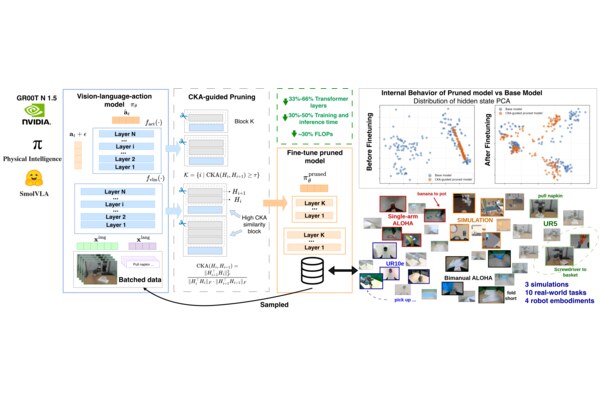
Finetuning Vision-Language-Action Models Requires Fewer Layers Than You Think
Gia-Binh Nguyen and Trong-Bao Ho and Thien-Loc Ha and Khoa Vo and Philip Lund Møller and Quang T. Nguyen and Long Dinh and Tung M. Luu and Tuan Quang Dam and Vu Duong and Trung Le and Nghi D. Q. Bui and Minh Vu and Tran Nguyen Le and An Thai Le and Hong Anh Le and Daniel Sonntag and James Zou and Jan Peters and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
Finetuning Vision-Language-Action Models Requires Fewer Layers Than You Think
Gia-Binh Nguyen and Trong-Bao Ho and Thien-Loc Ha and Khoa Vo and Philip Lund Møller and Quang T. Nguyen and Long Dinh and Tung M. Luu and Tuan Quang Dam and Vu Duong and Trung Le and Nghi D. Q. Bui and Minh Vu and Tran Nguyen Le and An Thai Le and Hong Anh Le and Daniel Sonntag and James Zou and Jan Peters and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
EquiVLA: A General Framework for Rotationally Equivariant Vision-Language-Action Models
Thien-Loc Ha and Quang-Tan Nguyen and Trong-Bao Ho and Long Dinh and Minh Duc Nguyen and Gia-Binh Nguyen and Pham Tri Quang and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
arXiv preprint
EquiVLA: A General Framework for Rotationally Equivariant Vision-Language-Action Models
Thien-Loc Ha and Quang-Tan Nguyen and Trong-Bao Ho and Long Dinh and Minh Duc Nguyen and Gia-Binh Nguyen and Pham Tri Quang and Minh N. Vu and Duy M. H. Nguyen and An Thai Le and Ngo Anh Vien
arXiv preprint
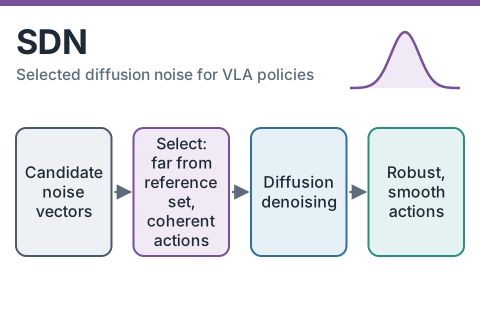
Self-Improving VLA Policies: Selected Diffusion Noise for Spurious-Robust Action Smoothing
Duc Minh Nguyen and Bao-Ngoc Dao and Tung M. Luu and Binh Gia Nguyen and Vinh Tong and Anji Liu and Vu N. Duong and Dung D. Le and Daniel Sonntag and Trung Le and Ngan Le and Jan Peters and An Thai Le and Minh Nhat Vu and Mathias Niepert and Khoa D. Doan and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
Self-Improving VLA Policies: Selected Diffusion Noise for Spurious-Robust Action Smoothing
Duc Minh Nguyen and Bao-Ngoc Dao and Tung M. Luu and Binh Gia Nguyen and Vinh Tong and Anji Liu and Vu N. Duong and Dung D. Le and Daniel Sonntag and Trung Le and Ngan Le and Jan Peters and An Thai Le and Minh Nhat Vu and Mathias Niepert and Khoa D. Doan and Duy M. H. Nguyen and Ngo Anh Vien
arXiv preprint
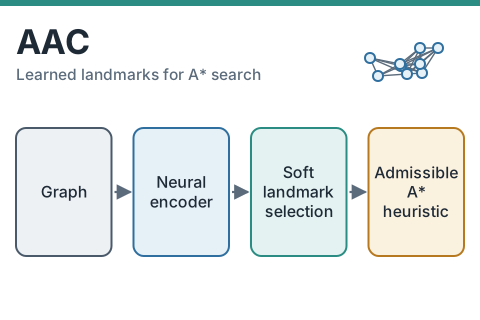
AAC: Admissible-by-Architecture Differentiable Landmark Compression for ALT
An T. Le and Ngo Anh Vien
arXiv preprint
AAC: Admissible-by-Architecture Differentiable Landmark Compression for ALT
An T. Le and Ngo Anh Vien
arXiv preprint
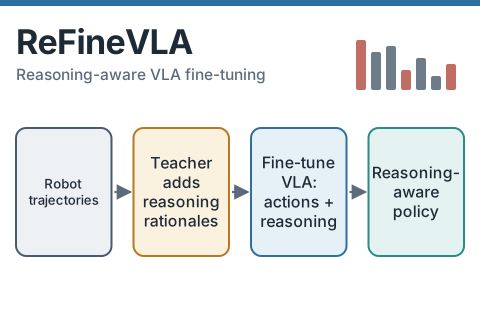
ReFineVLA: Multimodal Reasoning-Aware Generalist Robotic Policies via Teacher-Guided Fine-Tuning
Tuan Van Vo and Tan Q. Nguyen and Khang Nguyen and Nhat Xuan Tran and Duy H. M. Nguyen and An T. Le and Ngo Anh Vien and Minh Nhat Vu
arXiv preprint
ReFineVLA: Multimodal Reasoning-Aware Generalist Robotic Policies via Teacher-Guided Fine-Tuning
Tuan Van Vo and Tan Q. Nguyen and Khang Nguyen and Nhat Xuan Tran and Duy H. M. Nguyen and An T. Le and Ngo Anh Vien and Minh Nhat Vu
arXiv preprint
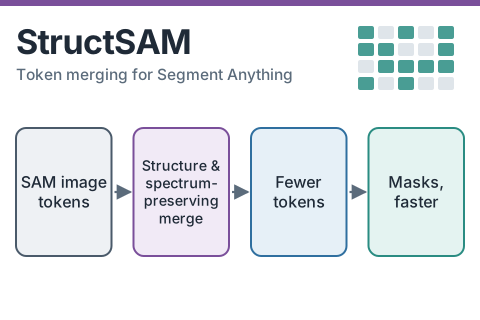
StructSAM: Structure- and Spectrum-Preserving Token Merging for Segment Anything Models
Duy M. H. Nguyen and Tuan A. Tran and Duong Nguyen and Siwei Xie and Trung Q. Nguyen and Mai T. N. Truong and Daniel Palenicek and An T. Le and Michael Barz and TrungTin Nguyen and Tuan Dam and Ngan Le and Minh Vu and Khoa D. Doan and Ngo Anh Vien and Pengtao Xie and James Zou and Daniel Sonntag and Jan Peters and Mathias Niepert
arXiv preprint
StructSAM: Structure- and Spectrum-Preserving Token Merging for Segment Anything Models
Duy M. H. Nguyen and Tuan A. Tran and Duong Nguyen and Siwei Xie and Trung Q. Nguyen and Mai T. N. Truong and Daniel Palenicek and An T. Le and Michael Barz and TrungTin Nguyen and Tuan Dam and Ngan Le and Minh Vu and Khoa D. Doan and Ngo Anh Vien and Pengtao Xie and James Zou and Daniel Sonntag and Jan Peters and Mathias Niepert
arXiv preprint
2025
How Many Tokens Do 3D Point Cloud Transformer Architectures Really Need?
Tuan Anh Tran and Duy Minh Ho Nguyen and Hoai-Chau Tran and Michael Barz and Khoa D Doan and Roger Wattenhofer and Vien Anh Ngo and Mathias Niepert and Daniel Sonntag and Paul Swoboda
Advances in Neural Information Processing Systems (NeurIPS)
How Many Tokens Do 3D Point Cloud Transformer Architectures Really Need?
Tuan Anh Tran and Duy Minh Ho Nguyen and Hoai-Chau Tran and Michael Barz and Khoa D Doan and Roger Wattenhofer and Vien Anh Ngo and Mathias Niepert and Daniel Sonntag and Paul Swoboda
Advances in Neural Information Processing Systems (NeurIPS)
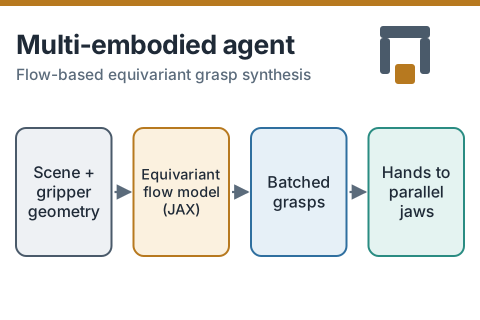
Towards a Multi-Embodied Grasping Agent
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
arXiv preprint
Towards a Multi-Embodied Grasping Agent
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
arXiv preprint
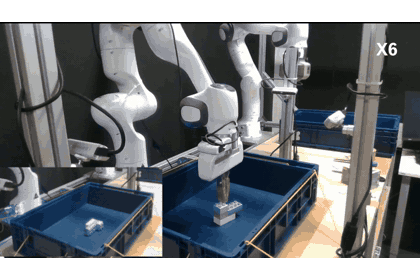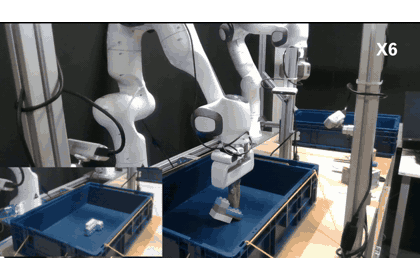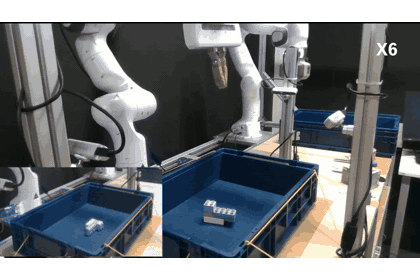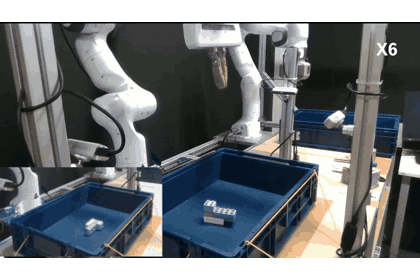
Enhancing Exploration With Diffusion Policies in Hybrid Off-Policy RL: Application to Non-Prehensile Manipulation
Huy Le and Tai Hoang and Miroslav Gabriel and Gerhard Neumann and Ngo Anh Vien
IEEE Robotics Autom. Lett. (RAL)
Enhancing Exploration With Diffusion Policies in Hybrid Off-Policy RL: Application to Non-Prehensile Manipulation
Huy Le and Tai Hoang and Miroslav Gabriel and Gerhard Neumann and Ngo Anh Vien
IEEE Robotics Autom. Lett. (RAL)
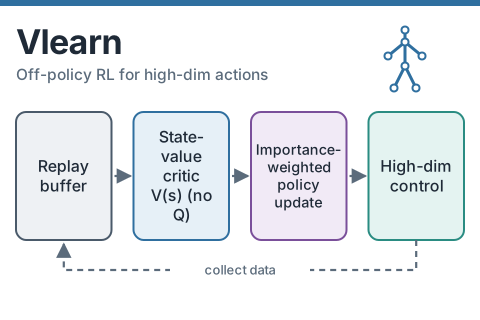
Efficient Off-Policy Learning for High-Dimensional Action Spaces
Fabian Otto and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
Efficient Off-Policy Learning for High-Dimensional Action Spaces
Fabian Otto and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
Geometry-aware RL for Manipulation of Varying Shapes and Deformable Objects
Tai Hoang and Huy Le and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
Geometry-aware RL for Manipulation of Varying Shapes and Deformable Objects
Tai Hoang and Huy Le and Philipp Becker and Ngo Anh Vien and Gerhard Neumann
The Thirteenth International Conference on Learning Representations, ICLR 2025, Singapore, April 24-28, 2025
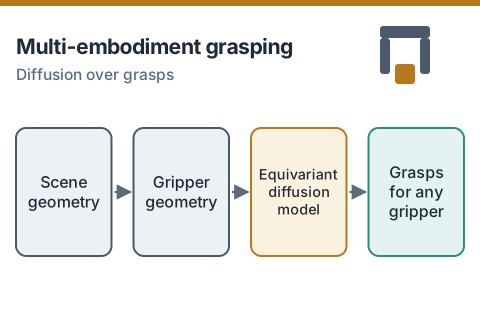
Diffusion for Multi-Embodiment Grasping
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
IEEE Robotics Autom. Lett. (RAL)
Diffusion for Multi-Embodiment Grasping
Roman Freiberg and Alexander Qualmann and Ngo Anh Vien and Gerhard Neumann
IEEE Robotics Autom. Lett. (RAL)
2024
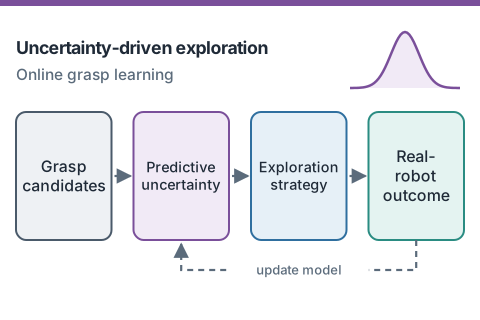
Uncertainty-driven Exploration Strategies for Online Grasp Learning
Yitian Shi and Philipp Schillinger and Miroslav Gabriel and Alexander Qualmann and Zohar Feldman and Hanna Ziesche and Ngo Anh Vien
IEEE International Conference on Robotics and Automation, ICRA 2024, Yokohama, Japan, May 13-17, 2024
Uncertainty-driven Exploration Strategies for Online Grasp Learning
Yitian Shi and Philipp Schillinger and Miroslav Gabriel and Alexander Qualmann and Zohar Feldman and Hanna Ziesche and Ngo Anh Vien
IEEE International Conference on Robotics and Automation, ICRA 2024, Yokohama, Japan, May 13-17, 2024
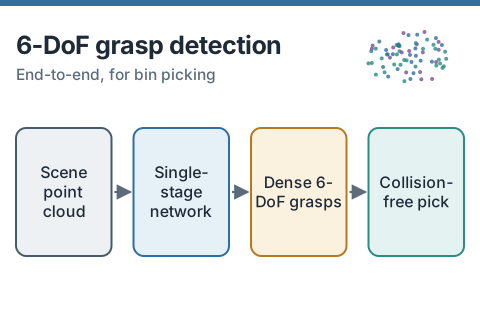
Efficient End-to-End Detection of 6-DoF Grasps for Robotic Bin Picking
Yushi Liu and Alexander Qualmann and Zehao Yu and Miroslav Gabriel and Philipp Schillinger and Markus Spies and Ngo Anh Vien and Andreas Geiger
IEEE International Conference on Robotics and Automation, {ICRA} 2024, Yokohama, Japan, May 13-17, 2024
Efficient End-to-End Detection of 6-DoF Grasps for Robotic Bin Picking
Yushi Liu and Alexander Qualmann and Zehao Yu and Miroslav Gabriel and Philipp Schillinger and Markus Spies and Ngo Anh Vien and Andreas Geiger
IEEE International Conference on Robotics and Automation, {ICRA} 2024, Yokohama, Japan, May 13-17, 2024
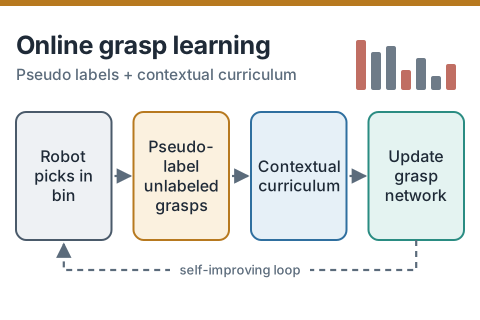
Pseudo Labeling and Contextual Curriculum Learning for Online Grasp Learning in Robotic Bin Picking
Huy Le and Philipp Schillinger and Miroslav Gabriel and Alexander Qualmann and Ngo Anh Vien
IEEE International Conference on Robotics and Automation, ICRA 2024, Yokohama, Japan, May 13-17, 2024
Pseudo Labeling and Contextual Curriculum Learning for Online Grasp Learning in Robotic Bin Picking
Huy Le and Philipp Schillinger and Miroslav Gabriel and Alexander Qualmann and Ngo Anh Vien
IEEE International Conference on Robotics and Automation, ICRA 2024, Yokohama, Japan, May 13-17, 2024
2023
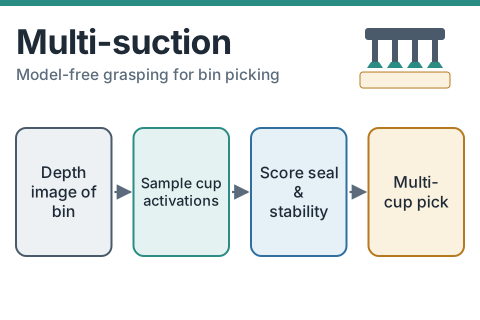
Model-Free Grasping with Multi-Suction Cup Grippers for Robotic Bin Picking
Philipp Schillinger and Miroslav Gabriel and Alexander Kuss and Hanna Ziesche and Ngo Anh Vien
{IROS}
Model-Free Grasping with Multi-Suction Cup Grippers for Robotic Bin Picking
Philipp Schillinger and Miroslav Gabriel and Alexander Kuss and Hanna Ziesche and Ngo Anh Vien
{IROS}
SA6D: Self-Adaptive Few-Shot 6D Pose Estimator for Novel and Occluded Objects
Ning Gao and Ngo Anh Vien and Hanna Ziesche and Gerhard Neumann
Conference on Robot Learning, CoRL 2023, 6-9 November 2023, Atlanta, GA, {USA}
SA6D: Self-Adaptive Few-Shot 6D Pose Estimator for Novel and Occluded Objects
Ning Gao and Ngo Anh Vien and Hanna Ziesche and Gerhard Neumann
Conference on Robot Learning, CoRL 2023, 6-9 November 2023, Atlanta, GA, {USA}
2022
A Hybrid Approach for Learning to Shift and Grasp with Elaborate Motion Primitives
Zohar Feldman and Hanna Ziesche and Ngo Anh Vien and Dotan Di Castro
2022 International Conference on Robotics and Automation, {ICRA} 2022, Philadelphia, PA, USA, May 23-27, 2022
A Hybrid Approach for Learning to Shift and Grasp with Elaborate Motion Primitives
Zohar Feldman and Hanna Ziesche and Ngo Anh Vien and Dotan Di Castro
2022 International Conference on Robotics and Automation, {ICRA} 2022, Philadelphia, PA, USA, May 23-27, 2022
FusionVAE: A Deep Hierarchical Variational Autoencoder for {RGB} Image Fusion
Fabian Duffhauss and Ngo Anh Vien and Hanna Ziesche and Gerhard Neumann
Computer Vision - {ECCV} 2022 - 17th European Conference, Tel Aviv, Israel, October 23-27, 2022, Proceedings, Part {XXXIX}
FusionVAE: A Deep Hierarchical Variational Autoencoder for {RGB} Image Fusion
Fabian Duffhauss and Ngo Anh Vien and Hanna Ziesche and Gerhard Neumann
Computer Vision - {ECCV} 2022 - 17th European Conference, Tel Aviv, Israel, October 23-27, 2022, Proceedings, Part {XXXIX}
Deep Black-Box Reinforcement Learning with Movement Primitives
Fabian Otto and Onur Celik and Hongyi Zhou and Hanna Ziesche and Ngo Anh Vien and Gerhard Neumann
Conference on Robot Learning, CoRL 2022, 14-18 December 2022, Auckland, New Zealand
Deep Black-Box Reinforcement Learning with Movement Primitives
Fabian Otto and Onur Celik and Hongyi Zhou and Hanna Ziesche and Ngo Anh Vien and Gerhard Neumann
Conference on Robot Learning, CoRL 2022, 14-18 December 2022, Auckland, New Zealand
2021
Non-local Graph Convolutional Network for joint Activity Recognition and Motion Prediction
Dianhao Zhang and Ngo Anh Vien and Mien Van and Se{\'{a}}n F. McLoone
IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2021, Prague, Czech Republic, September 27 - Oct. 1, 2021
Non-local Graph Convolutional Network for joint Activity Recognition and Motion Prediction
Dianhao Zhang and Ngo Anh Vien and Mien Van and Se{\'{a}}n F. McLoone
IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2021, Prague, Czech Republic, September 27 - Oct. 1, 2021
Residual Feedback Learning for Contact-Rich Manipulation Tasks with Uncertainty
Alireza Ranjbar and Ngo Anh Vien and Hanna Ziesche and Joschka Boedecker and Gerhard Neumann
IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2021, Prague, Czech Republic, September 27 - Oct. 1, 2021
Residual Feedback Learning for Contact-Rich Manipulation Tasks with Uncertainty
Alireza Ranjbar and Ngo Anh Vien and Hanna Ziesche and Joschka Boedecker and Gerhard Neumann
IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2021, Prague, Czech Republic, September 27 - Oct. 1, 2021
2018
Bayesian Functional Optimization
Ngo Anh Vien and Heiko Zimmermann and Marc Toussaint
Proceedings of the Thirty-Second AAAI Conference on Artificial Intelligence, (AAAI-18), the 30th innovative Applications of Artificial Intelligence (IAAI-18), and the 8th AAAI Symposium on Educational Advances in Artificial Intelligence (EAAI-18), New Orleans, Louisiana, USA, February 2-7, 2018
Bayesian Functional Optimization
Ngo Anh Vien and Heiko Zimmermann and Marc Toussaint
Proceedings of the Thirty-Second AAAI Conference on Artificial Intelligence, (AAAI-18), the 30th innovative Applications of Artificial Intelligence (IAAI-18), and the 8th AAAI Symposium on Educational Advances in Artificial Intelligence (EAAI-18), New Orleans, Louisiana, USA, February 2-7, 2018
2017
Inverse KKTLearning cost functions of manipulation tasks from demonstrations
Peter Englert and Ngo Anh Vien and Marc Toussaint
Int. J. Robotics Res.
Inverse KKTLearning cost functions of manipulation tasks from demonstrations
Peter Englert and Ngo Anh Vien and Marc Toussaint
Int. J. Robotics Res.
2016
Policy Search in Reproducing Kernel Hilbert Space
Ngo Anh Vien and Peter Englert and Marc Toussaint
Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence, IJCAI 2016, New York, NY, USA, 9-15 July 2016
Policy Search in Reproducing Kernel Hilbert Space
Ngo Anh Vien and Peter Englert and Marc Toussaint
Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence, IJCAI 2016, New York, NY, USA, 9-15 July 2016
Relational activity processes for modeling concurrent cooperation
Marc Toussaint and Thibaut Munzer and Yoan Mollard and Li Yang Wu and Ngo Anh Vien and Manuel Lopes
2016 IEEE International Conference on Robotics and Automation, {ICRA} 2016, Stockholm, Sweden, May 16-21, 2016
Relational activity processes for modeling concurrent cooperation
Marc Toussaint and Thibaut Munzer and Yoan Mollard and Li Yang Wu and Ngo Anh Vien and Manuel Lopes
2016 IEEE International Conference on Robotics and Automation, {ICRA} 2016, Stockholm, Sweden, May 16-21, 2016
2015
POMDP manipulation via trajectory optimization
Ngo Anh Vien and Marc Toussaint
2015 IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2015, Hamburg, Germany, September 28 - October 2, 2015
POMDP manipulation via trajectory optimization
Ngo Anh Vien and Marc Toussaint
2015 IEEE/RSJ} International Conference on Intelligent Robots and Systems, {IROS} 2015, Hamburg, Germany, September 28 - October 2, 2015
2014
Model-Based Relational {RL} When Object Existence is Partially Observable
Ngo Anh Vien and Marc Toussaint
Proceedings of the 31th International Conference on Machine Learning, {ICML} 2014, Beijing, China, 21-26 June 2014
Model-Based Relational {RL} When Object Existence is Partially Observable
Ngo Anh Vien and Marc Toussaint
Proceedings of the 31th International Conference on Machine Learning, {ICML} 2014, Beijing, China, 21-26 June 2014
2013
Upper Confidence Weighted Learning for Efficient Exploration in Multiclass Prediction with Binary Feedback
Hung Quoc Ngo and Matthew David Luciw and Ngo Anh Vien and J{\"{u}}rgen Schmidhuber
IJCAI 2013, Proceedings of the 23rd International Joint Conference on Artificial Intelligence, Beijing, China, August 3-9, 2013
Upper Confidence Weighted Learning for Efficient Exploration in Multiclass Prediction with Binary Feedback
Hung Quoc Ngo and Matthew David Luciw and Ngo Anh Vien and J{\"{u}}rgen Schmidhuber
IJCAI 2013, Proceedings of the 23rd International Joint Conference on Artificial Intelligence, Beijing, China, August 3-9, 2013
Reasoning with Uncertainties Over Existence of Objects
Ngo Anh Vien and Marc Toussaint
2013 AAAI Fall Symposia, Arlington, Virginia, USA, November 15-17, 2013
Reasoning with Uncertainties Over Existence of Objects
Ngo Anh Vien and Marc Toussaint
2013 AAAI Fall Symposia, Arlington, Virginia, USA, November 15-17, 2013
2010
Monte Carlo Value Iteration for Continuous-State POMDPs
Haoyu Bai and David Hsu and Wee Sun Lee and Ngo Anh Vien
Algorithmic Foundations of Robotics {IX} - Selected Contributions of the Ninth International Workshop on the Algorithmic Foundations of Robotics, {WAFR} 2010, Singapore, December 13-15, 2010
Monte Carlo Value Iteration for Continuous-State POMDPs
Haoyu Bai and David Hsu and Wee Sun Lee and Ngo Anh Vien
Algorithmic Foundations of Robotics {IX} - Selected Contributions of the Ninth International Workshop on the Algorithmic Foundations of Robotics, {WAFR} 2010, Singapore, December 13-15, 2010